
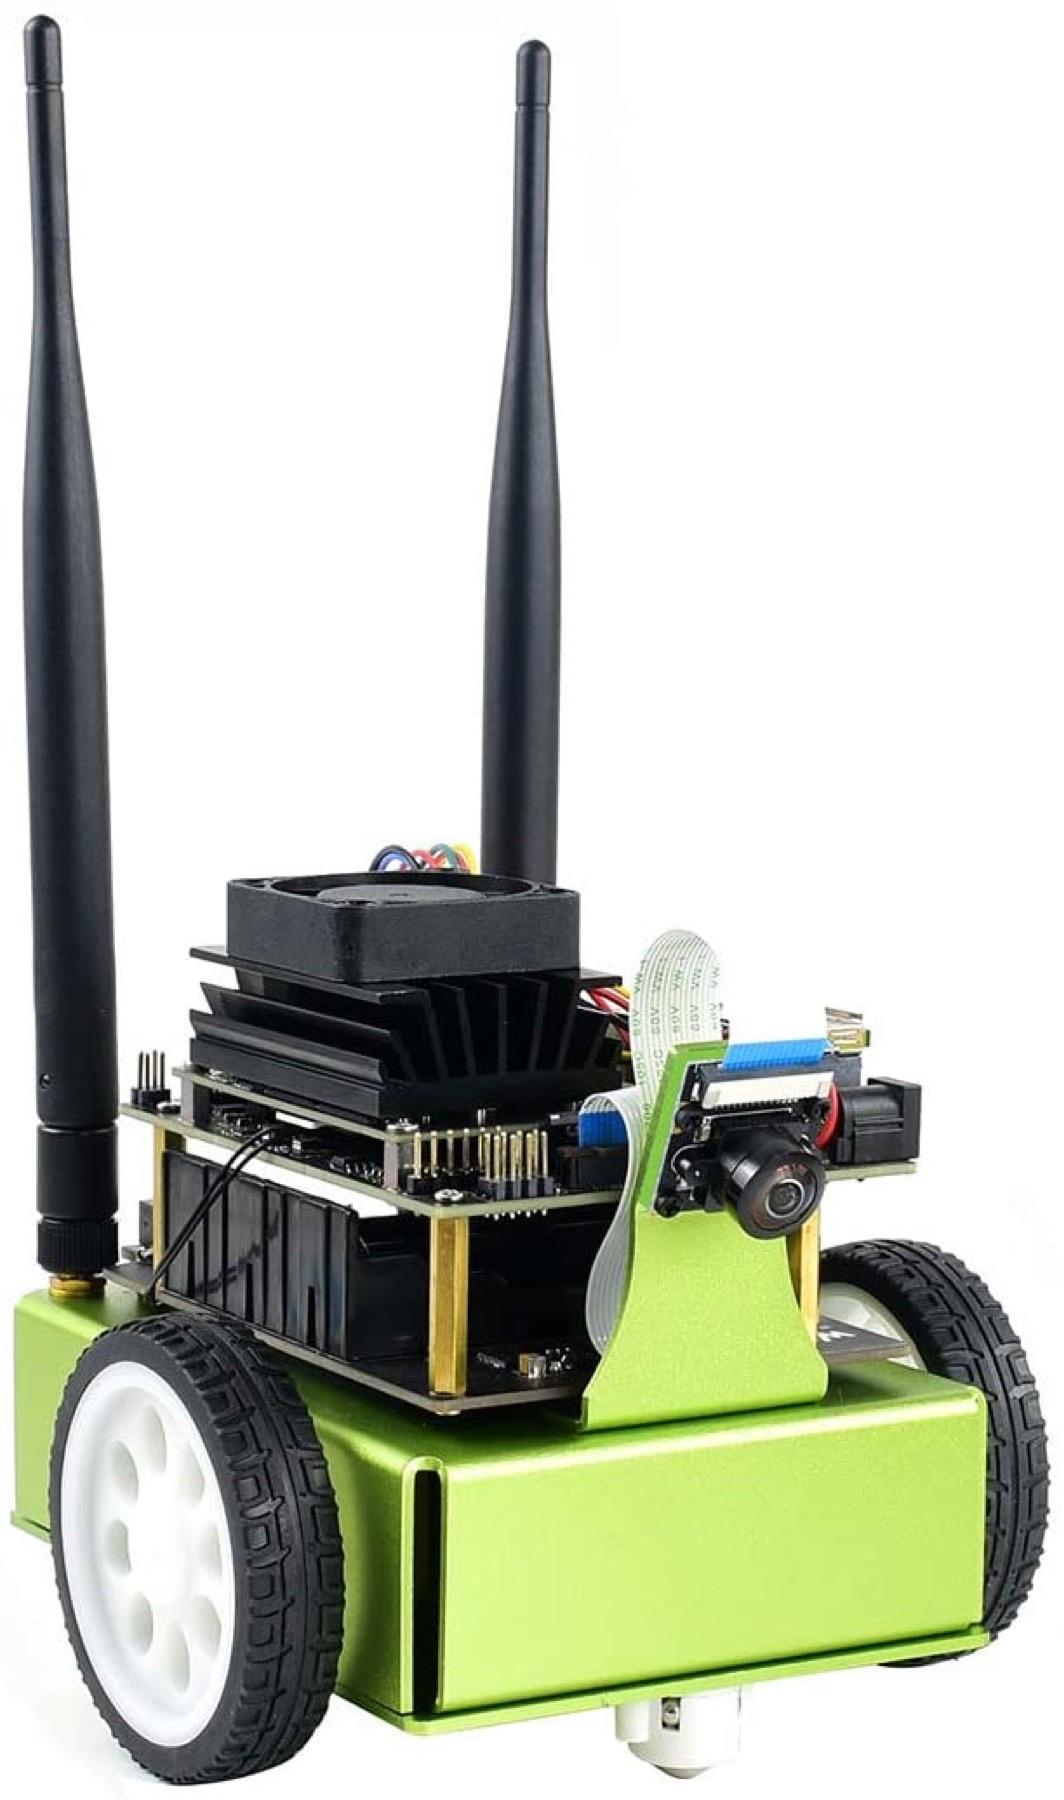
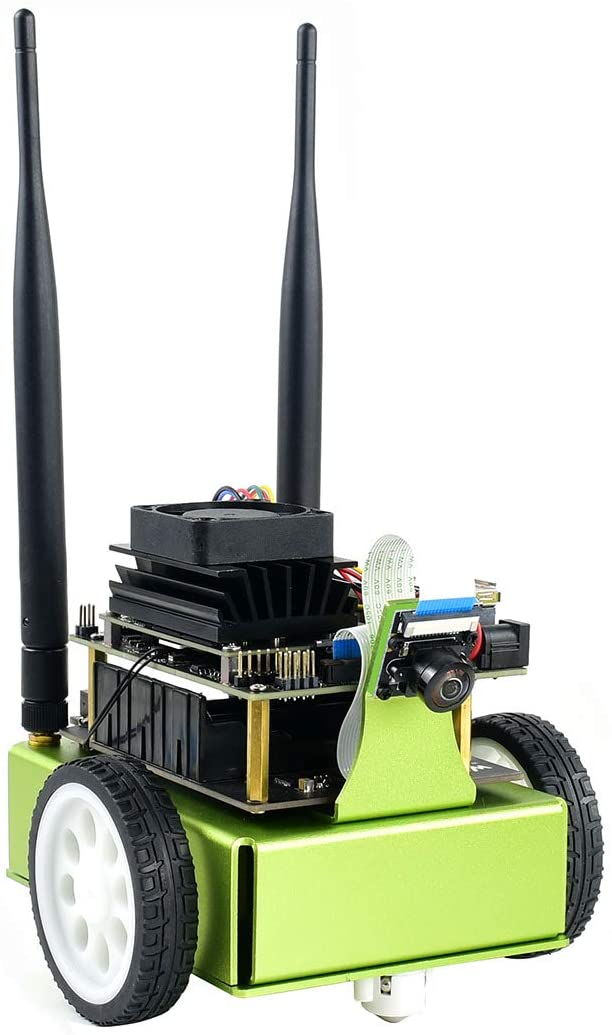
01 / Project overview
JetBot is NVIDIA’s open-source educational robot platform. Its lessons progress from basic movement to camera-based tasks such as collision avoidance, and the official project recognizes Waveshare among the third-party kit variants. A Waveshare build should begin with that kit’s hardware documentation and software image before following the general JetBot lessons.
02 / Materials & software
- Waveshare JetBot-compatible kit
- matching NVIDIA Jetson Nano platform and software image
- camera
- motors and power hardware
03 / Compatibility & setup notes
Different JetBot kits use different motor drivers, wiring and software images. NVIDIA reference instructions alone do not establish compatibility with every Waveshare kit.
AI CONCEPT
A conceptual camera-guided robot learning to follow a path. AI-generated illustration; not the original project, a wiring guide or a tested build.
04 / Build the project
- Identify the exact Waveshare kit and its supported Jetson software image.
- Check the camera and motor-control examples supplied for that variant.
- Run the basic motion lesson first, then collect data and follow the camera-based learning workflow.
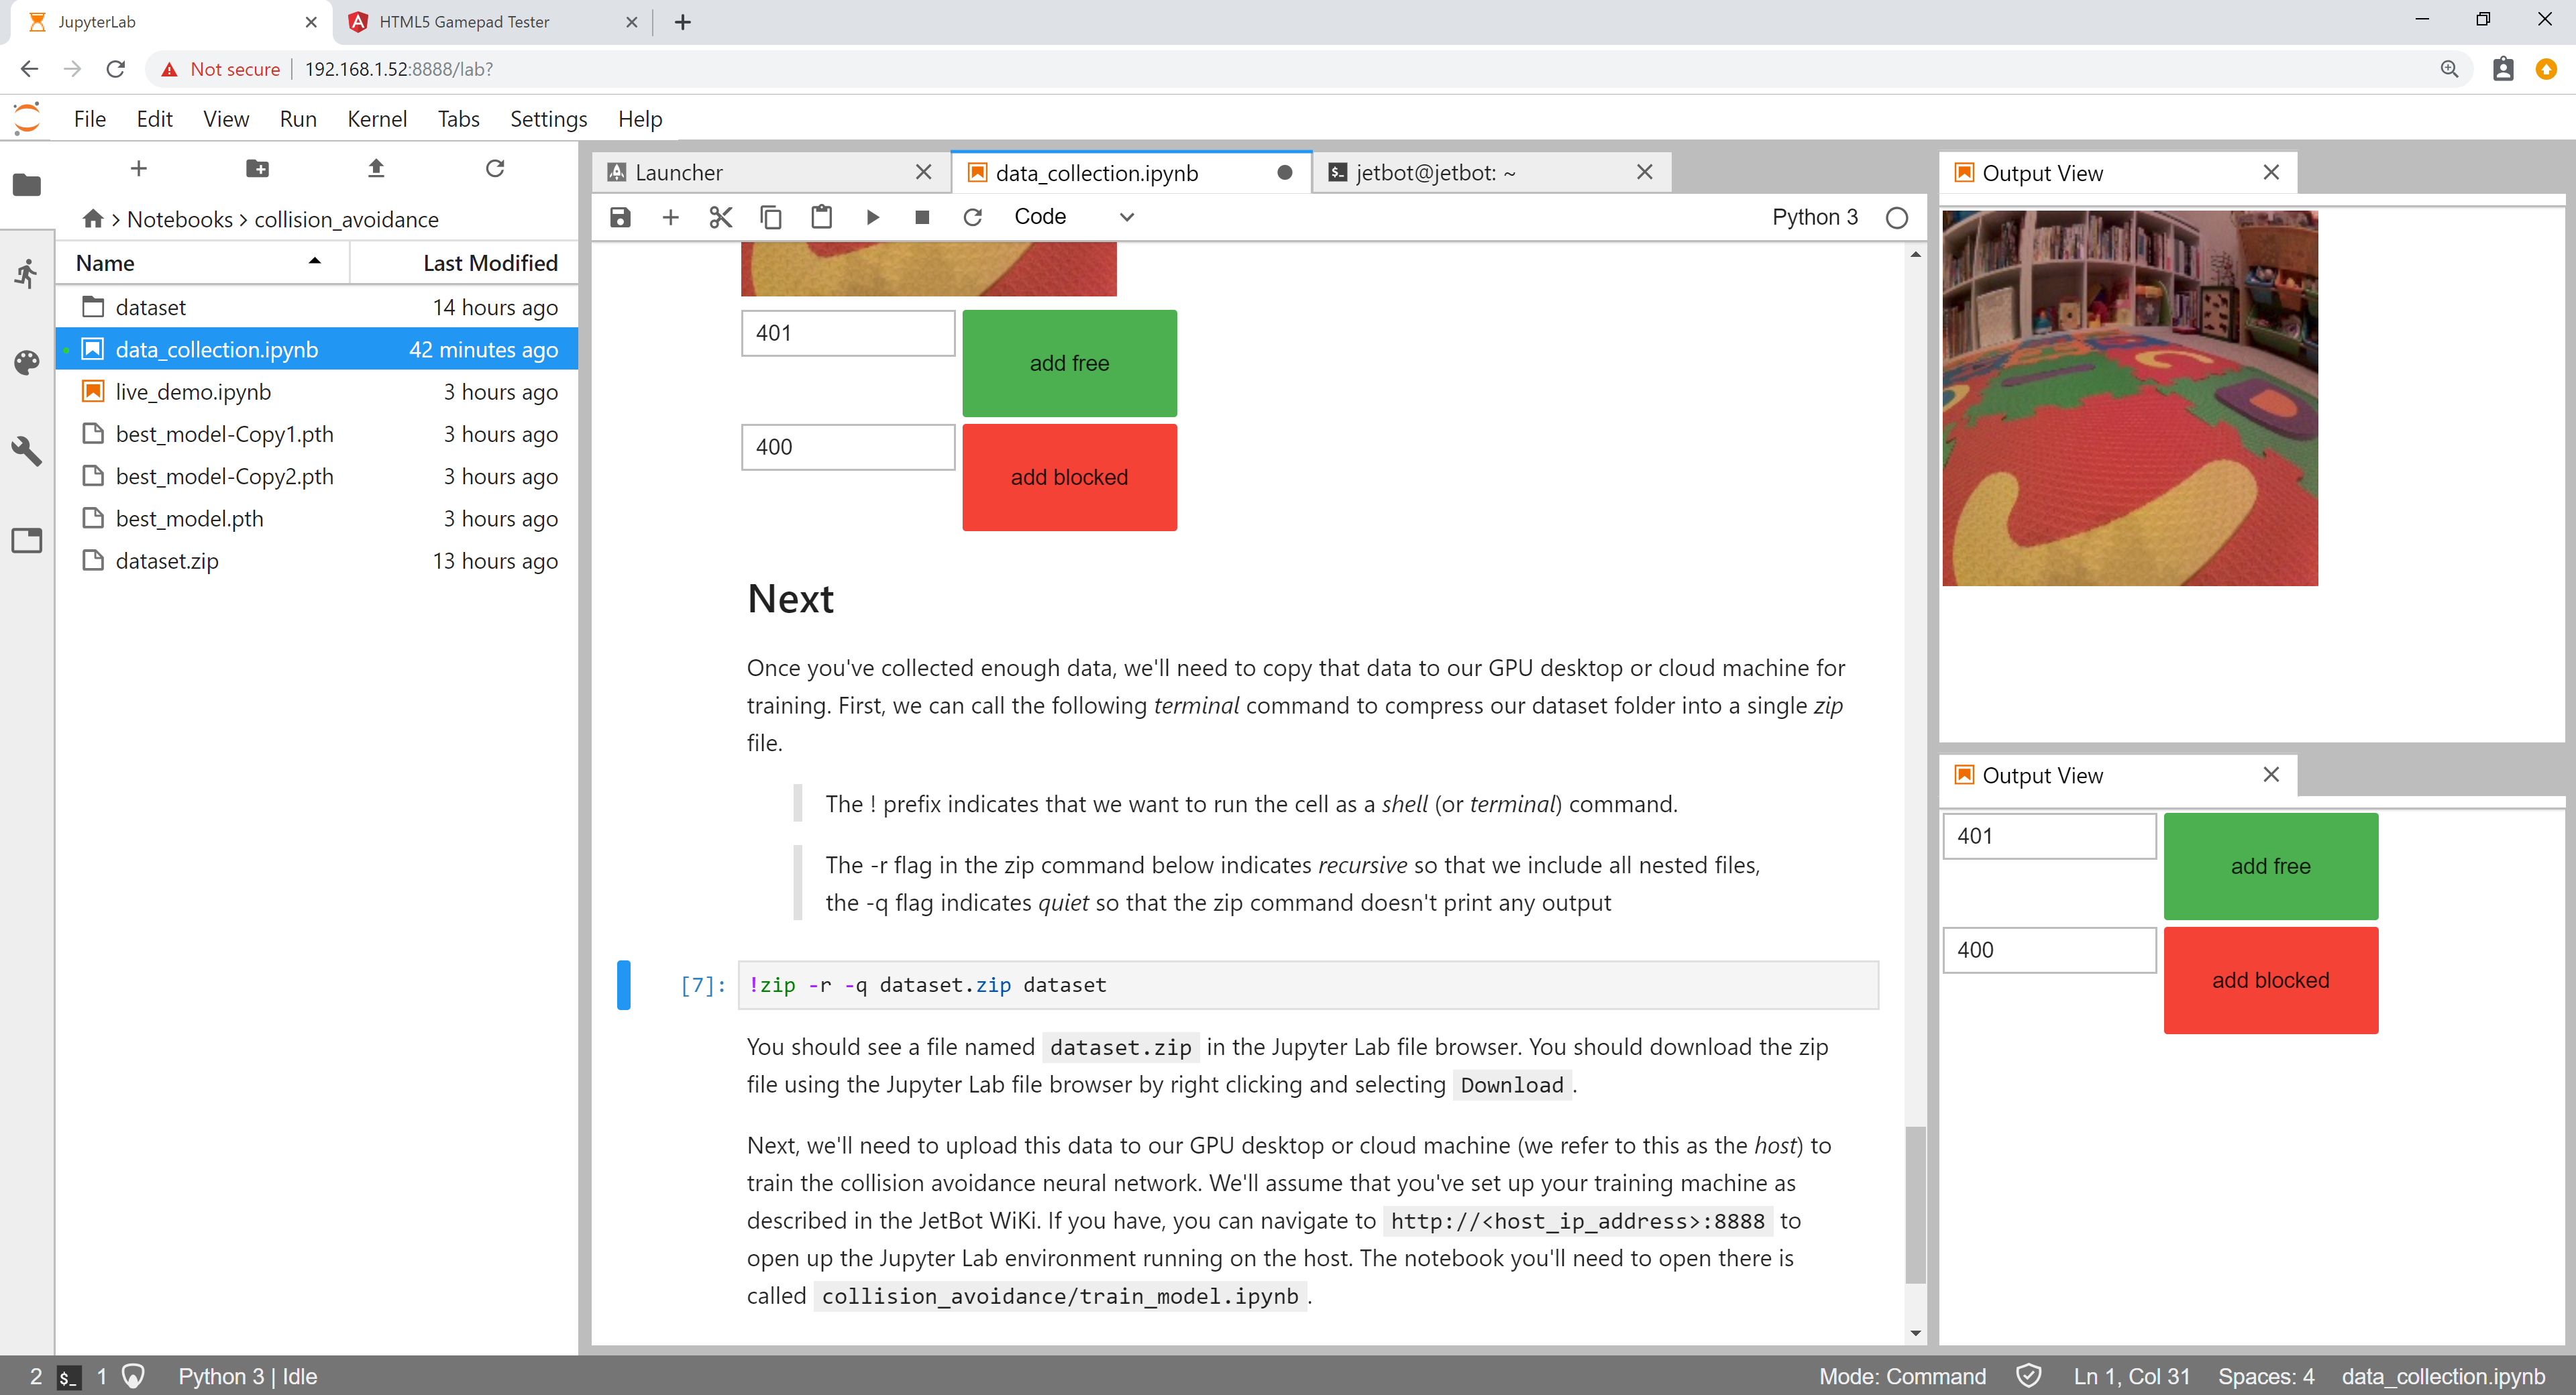
FROM THE ORIGINAL PROJECT
NVIDIA’s original data-collection lesson interface. This software example is separate from vendor-specific assembly details.
NVIDIA-AI-IOT/jetbot · View original image
05 / Check the result
Begin with the wheels clear of the desk, confirm left/right motor direction and verify a stop command. Test camera output before collecting training images.
PineMux build note: Keep a record of the board revision, firmware version and first successful test. Follow the upstream guide for exact pins and commands.
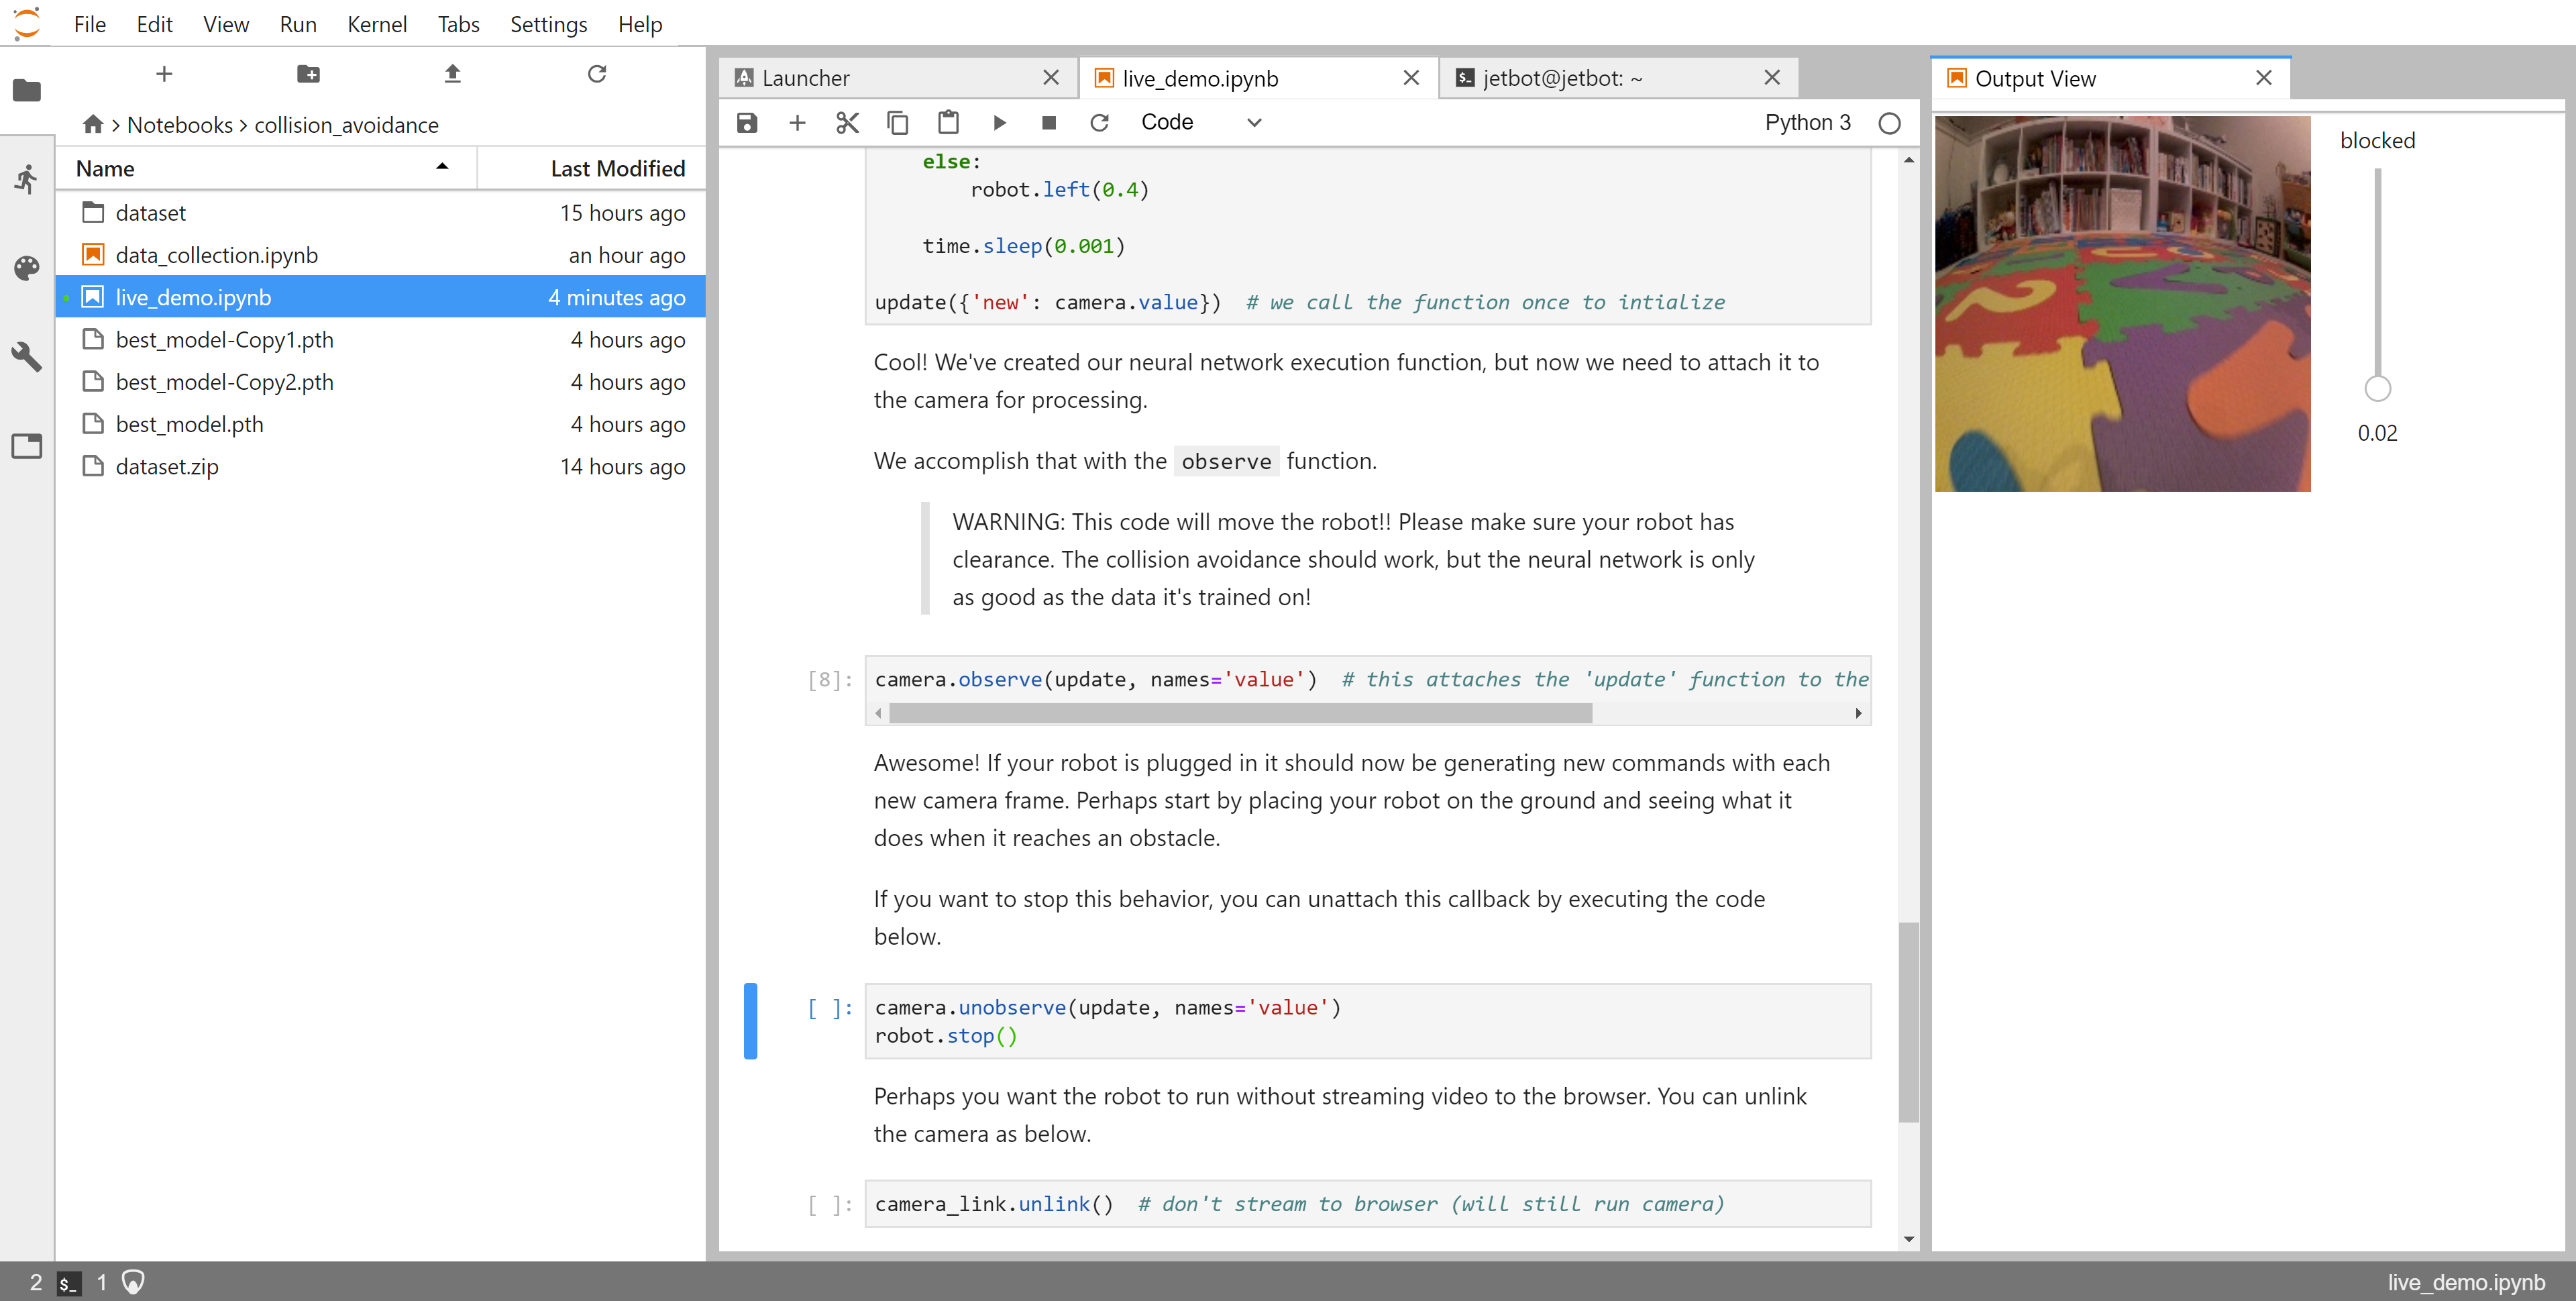
FROM THE ORIGINAL PROJECT
The upstream collision-avoidance lesson demonstrates the live camera workflow.
NVIDIA-AI-IOT/jetbot · View original image
06 / Sources & build notes
Upstream attention: 3,338 GitHub stars, checked 30 September 2026. Stars indicate community interest, not a reliability guarantee.
Original project by NVIDIA-AI-IOT. This PineMux editorial overview is based on the linked primary source; PineMux has not bench-tested this build.